 Contextual stock photography, not a Vitruvex facility, employee or customer deployment.
DEVELOPED AS ONE SYSTEM
Mechanics, control and wearer fit.
A wearable system depends on more than its motors. The frame, contact points and relationship between control and movement all matter. We develop these elements together.
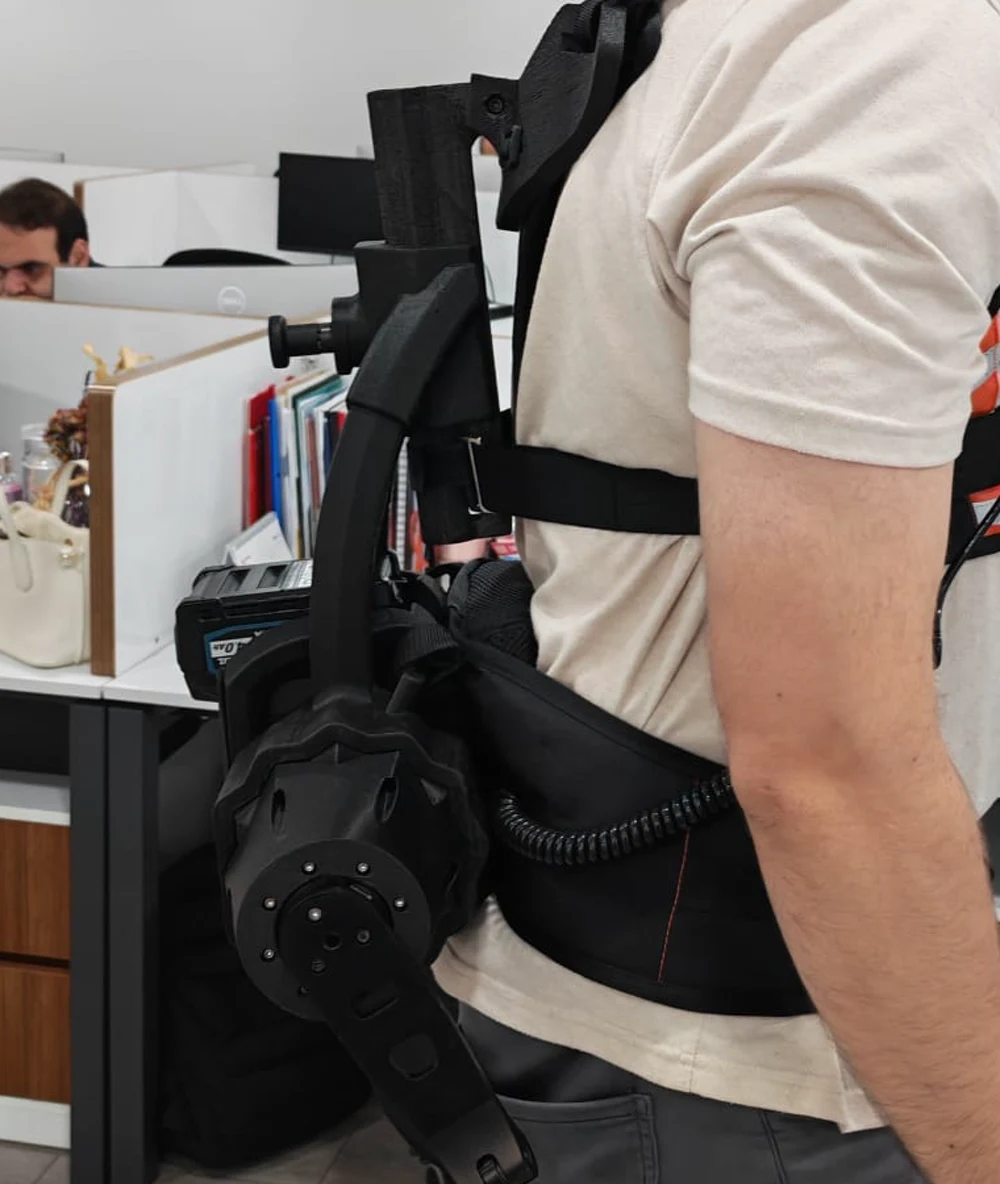
Actual V-UP prototype photograph and frames from prototype testing. September–October 2026.
01 / MECHANICAL ARCHITECTURE
Where movement meets the body.
The back frame, waist and thigh interfaces define the wearable system’s relationship with the body. Adjustability, component layout and movement compatibility are evaluated together.
Frame
The structure around the back and waist carries the motor assembly and connections.
Linkage
A short upper arm, intermediate joint and lower connecting arm lead to the thigh interface.
Body interface
Above-knee thigh connections are considered alongside textile elements adjusted to the wearer.
02 / CONTROL DEVELOPMENT
A system in relation to movement.
Motor feedback
Evaluating movement for control development
Control electronics
Developing assistance behaviour
User interface
Interaction between the system and its wearer
Data monitoring and connected-use features remain under development.
V-UP03 / V-NEURO
Another perspective on human–robot interaction.
V-NEURO is a separate R&D programme exploring brain–computer interfaces and robotic interaction.
Research stageThe research scope and evaluation methods can be discussed in a technical meeting.
Technical discussionStart with your technical question.
Let’s discuss mechanical design, control or an R&D collaboration.
Technical discussion